Understand motion.
Build the model.
From energy storage to controlled drives and synchronous generators. Connect physical principles, equations and experiments you can check.
No account required · progress saved locally
Twenty steps to your own model
Study in sequence or return to the topic you need.
What is a transient?
Why current and speed cannot change instantly, and how to read time responses.
The mathematics of change
Derivatives, integrals, initial-value problems and the connection between poles and responses.
The RL circuit
Inductance, current continuity and an exact reference for numerical models.
Rotational mechanics
Torque, inertia, viscous friction and the conversion between angular speed and rpm.
Electromechanical conversion
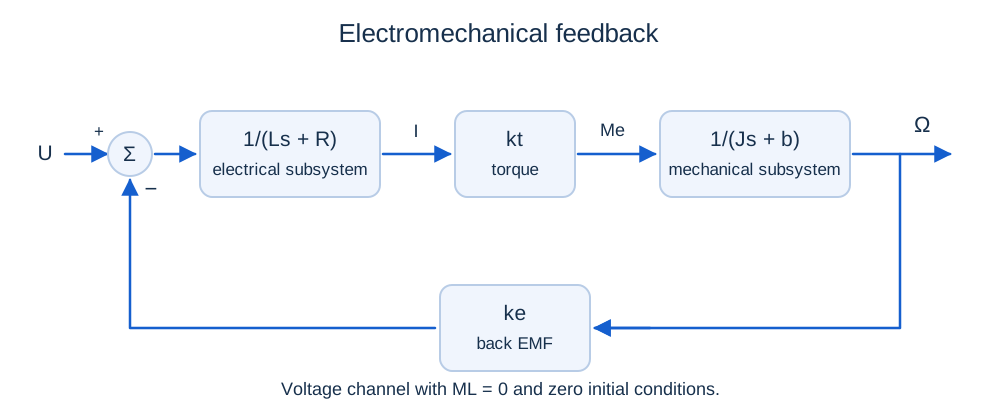
How current produces torque and rotation produces back EMF and internal feedback.
Building the motor model
Two coupled equations, one parameter set and an independent steady-state check.
Numerical methods without magic
Euler, adaptive integration and independent checks of numerical accuracy.
Startup and a load step
Read current, speed and torque as one connected causal response.
Braking and reversal
Current, torque and power signs as a drive decelerates or reverses.
A first speed controller
P and PI control, voltage saturation and integrator anti-windup.
Identifying motor parameters
Estimate resistance, inductance, back-EMF constant, inertia and friction from measurements.
PWM conversion and current ripple
Duty ratio, averaged and switched models, current ripple and additional losses.
Cascaded current and speed control
Tune an inner current PI loop, then an outer speed loop with explicit limits.
A two-mass drive and elastic oscillations
Shaft compliance, natural frequency, damping, resonance and antiresonance.
Digital control and delays
Exact discretization, digital PI, computation delay, quantization and z-plane stability.
Synchronous generators and per-unit quantities
Rotating fields, synchronous speed and consistent three-phase bases.
Load angle, active power and reactive power
The generator phasor model, the power–angle curve and excitation.
Rotor dynamics and the swing equation
Inertia, power imbalance and electromechanical generator oscillations.
Voltage dips and transient stability
Rotor acceleration during a disturbance, grid recovery and loss of synchronism.
Synchronous generator laboratory
Design an experiment, check the numerical solution and report reproducible results.
Synchronous generator laboratory
From per-unit quantities to transient stability: change parameters, compare responses and export your results.
Open the interactive model →Lessons 16–20 explain the equations, assumptions and numerical checks behind the simulation.
Start the generator module →